Simple, trusted, and reliable working platforms and software
A unified autonomy stack and a modular, scalable family of AUVs engineered to be operator-friendly, rapidly deployable, and resilient against the harshest maritime environments.
The mind behind the swarm - in command, not on a leash
Poseidon™ is Strydent’s proprietary autonomous operation software. It fuses sensing, navigation, and spatial communications into one decision-making system that runs entirely on the vehicle – coordinating a single asset or a swarm of thousands with human-in-the-loop oversight enables robust, steerable, and controllable autonomous operations while preserving an unbroken chain of command, meaningful human authority to direct and intervene, and clear lines of responsibility and accountability for action and decision.
Built operator-first, Poseidon™ turns mission intent into autonomous action: define the objective, deploy the fleet, and let the platform sense, decide, and adapt in real time beneath the surface.
Pilots required
From mission intent to autonomous action
Poseidon™ closes the loop on the vehicle – four stages, running continuously and independently across the fleet.
Task
Operators define mission intent and area of operations in plain objectives — not waypoint-by-waypoint piloting. Poseidon™ allocates the work across available vehicles.
Sense
Each vehicle builds a picture from onboard sonar, optical, and environmental sensors, fixing its own position by dead reckoning where GPS is degraded or denied.
Decide
Edge AI classifies what it sees and chooses the next action on the vehicle — no waiting on a link home, no central point of failure.
Coordinate
Vehicles share a common operating picture over the spatial comms layer, synchronizing effects and re-tasking automatically as the mission evolves.
Integrated, Full Spectrum
Communications
Poseidon™ fuses optical, acoustic, and RF signaling into a single resilient link – keeping the swarm coherent underwater with low probability of detection and interception.
Optical
Cutting edge, short-range line-of-sight links for dense, fast coordination between nearby vehicles.
Acoustic
Subsea underwater messaging that holds the fleet together across distance where light and RF can't reach.
RF
User defined signal profile to command and to surface, air, and space assets while units are surfaced.
Resilient In The
Harshest Waters
Poseidon™ assumes the worst conditions by default: intermittent comms, no GPS, jamming, and loss of units. The platform degrades gracefully – the swarm keeps the mission alive even as individual vehicles drop.
- No Single Point of Failure - tasking is distributed and reassigned automatically across the fleet.
- Comms-Denied Operation - vehicles continue the mission autonomously when links drop, then re-sync on contact.
- Low Signature - LPD/LPI signaling profiles keep the fleet quiet in contested water.
Simple to command, trusted in the field
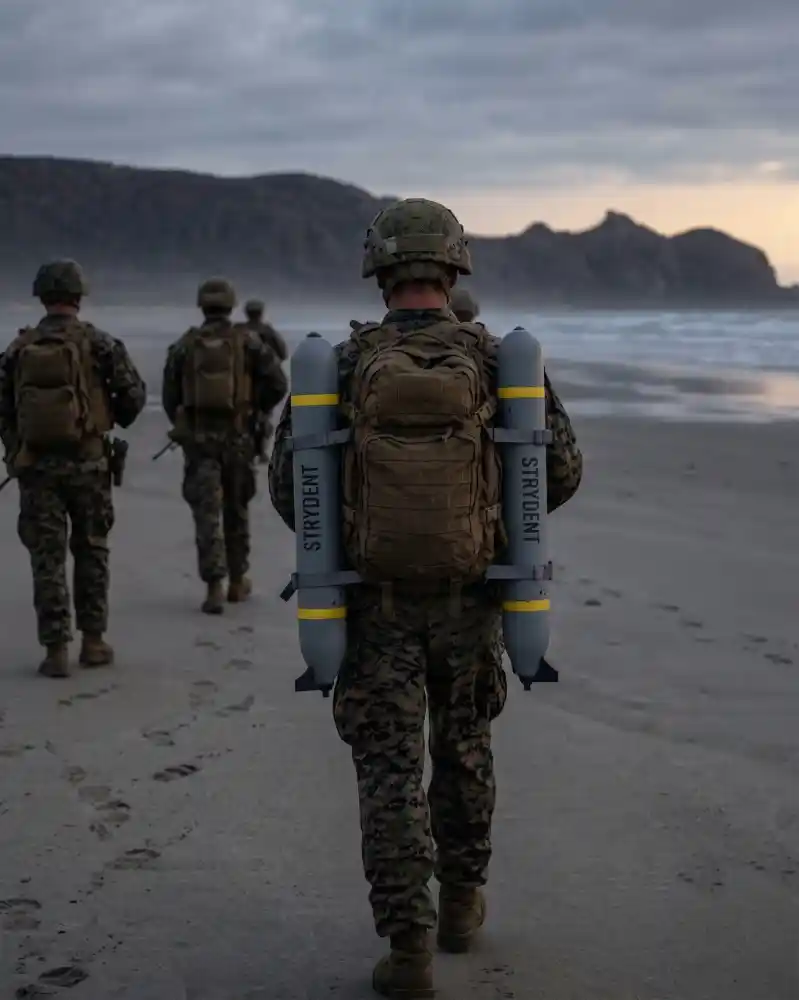
Poseidon™ is designed for the operator at the water’s edge – fast to deploy, easy to direct, and dependable when it matters.
Rapid Deployment
Crane-free, man-portable launch from boat, aircraft, or shore — vehicles begin coordinating the moment they hit the water.
Autonomous Navigation
Positionally accurate even in GPS-degraded/denied environments, diverse capabilities include hardened sensors, celestial navigation, terrain-relative positioning/obstacle avoidance — no active piloting required.
True-Swarm Effects
Coordinate and synchronize ten, a hundred, or thousands of vehicles toward a single objective, re-tasking on the fly.
Edge AI
On-vehicle intelligence senses, classifies, and decides without waiting on a link home — autonomy at the edge.
Common Operating Picture
Every vehicle shares a precise, real-time fix on itself and its neighbors, keeping the swarm coherent underwater.
Trusted & Secure
Resilient, low-signature signaling and graceful degradation make Poseidon™ dependable in contested environments.
Poseidon™ runs the whole fleet
The same autonomy software scales across the Strydent AUV family – from the attritable Model 100 to the deep-water Model 4000.
Capability | What it delivers | Fleet-wide |
|---|---|---|
Autonomous Navigation | GPS-degraded/denied, station-keeping, and obstacle avoidance | Standard |
Spatial Communications | Optical + acoustic + RF fusion across the swarm | Standard |
True-Swarm Coordination | Distributed tasking and synchronized effects | Standard |
Edge AI & Classification | On-vehicle sensing, decision-making, and re-tasking | Standard |
Modular Payloads | SAS, optical imaging, CTD, and mission-specific sensors | Configurable |
Depth Envelope | Scales with platform — 100m to 4,000m+ | By platform |
Request a Poseidon™ demonstration
Tell us about your mission and we’ll arrange a briefing or live demonstration of the Poseidon™ autonomy stack and the Strydent AUV fleet.